DIVISION 03 • VEYRONIX DETECTION

Computer Vision & Intelligent Physical-World Detection.

We develop real-time computer vision models, neural face detection, object tracking, and edge AI pipelines that bring visual intelligence to camera systems and autonomous hardware.

COMPUTER VISION FACE DETECTION TARGET TRACKING AUTONOMOUS DRONES EDGE AI
Built & Tested in the Physical World: We engineer computer vision algorithms that operate outside the screen — powering actual autonomous hardware and real-time camera systems.
REAL-WORLD FIELD TEST
DRONE & OPTICAL TRACKING
CORE VISION CAPABILITIES

Precision Applied AI Across Four Technical Pillars.

From high-speed video feeds to embedded edge hardware, we build low-latency computer vision pipelines.

Detection

Real-time face detection, object localization, and YOLO-based boundary classification on live video streams.

  • Haar Cascade & Neural face models
  • Multi-object bounding box overlays

Recognition

Biometric facial landmark extraction, identity verification, and visual feature classification for access and telemetry.

  • Facial landmark mesh mapping
  • Confidence scoring & verification

Target Tracking

Continuous click-to-lock target identification, centroid trajectory calculation, and spatial displacement tracking.

  • Centroid displacement vectors
  • Dynamic bounding box scaling

Edge & Hardware AI

Embedded vision algorithms optimized for edge processors, robotic gimbals, and autonomous drone flight loops.

  • Decoupled worker thread pools
  • High-frequency PID stabilization
FLAGSHIP ENGINEERING CASE STUDY

Aervion: Autonomous Vision & Flight Navigation.

APPLIED ROBOTICS & COMPUTER VISION

Aervion Flight Intelligence

A real-world applied computer vision and drone flight control project developed in Python and OpenCV with DJI Tello integration. Features real-time neural face detection, click-to-lock target selection, and autonomous target following.

Key Architectural Breakthrough:

Expensive computer vision inference originally bottlenecked the 50Hz flight control loop. We re-architected the system to decouple optical processing from flight stabilization using asynchronous worker threads.
Read Full Technical Breakdown ↗ Discuss Vision Project →
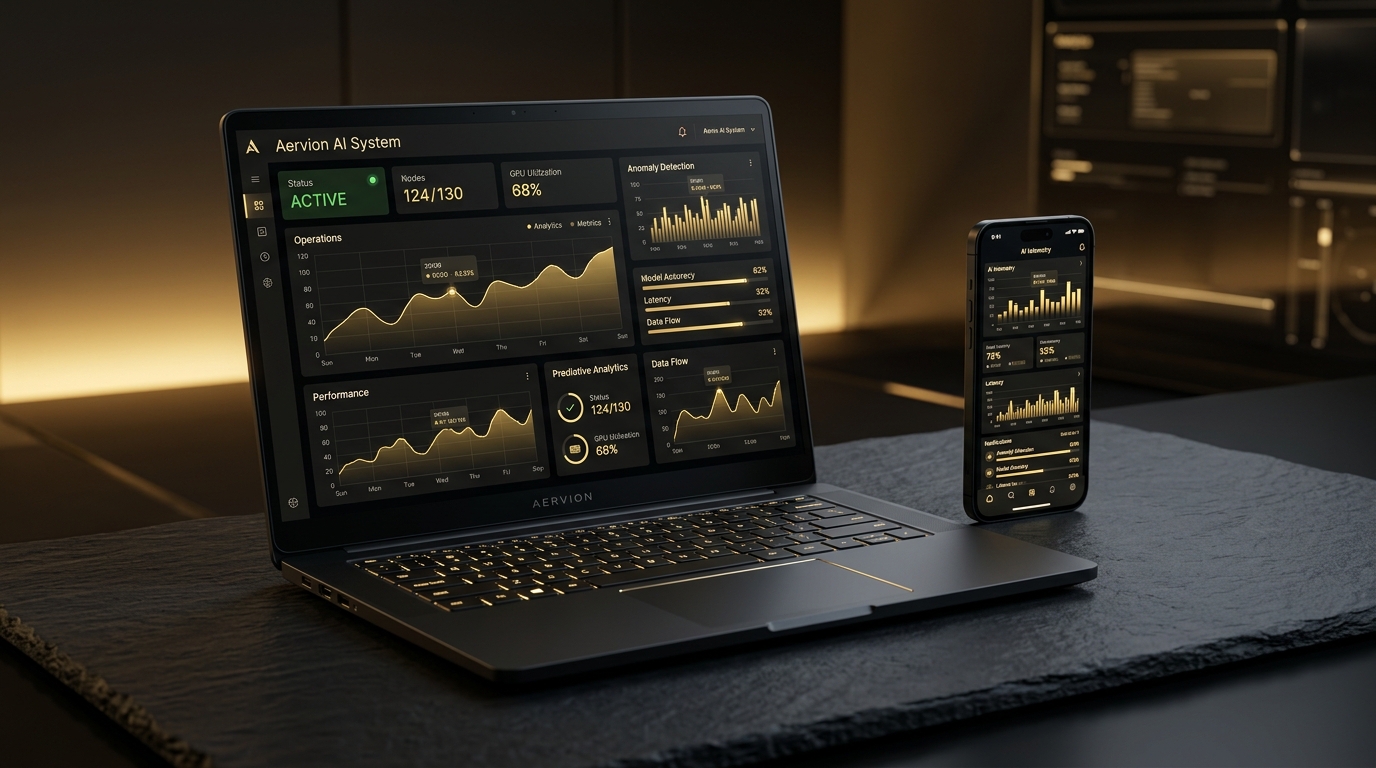
Aervion Computer Vision Dashboard
PHYSICAL-WORLD AI ENGINEERING

Need Custom Computer Vision Systems?

From tracking algorithms to camera-based AI monitoring and robotics integration, let's explore your technical scope.

Start a Conversation →